Research
We study how geometry, materials and instability can be programmed to create reconfigurable structures and mechanical metamaterials with adaptive functions.
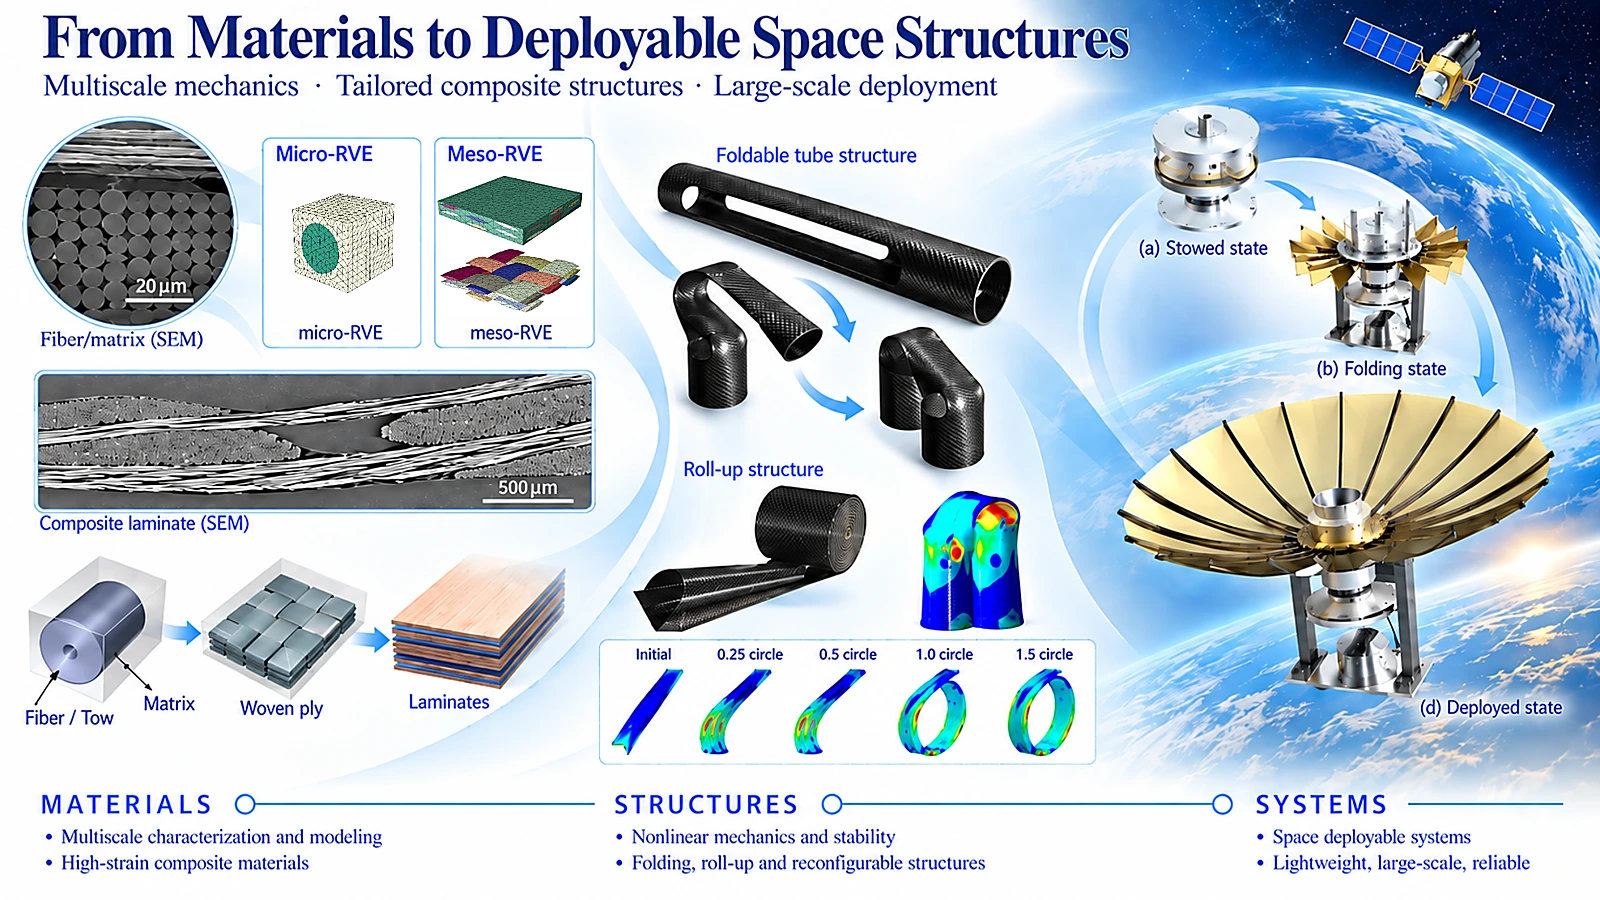
Deployable Structures
We study lightweight deployable structures from high-strain composites and nonlinear folding to roll-up and large-scale space deployment.
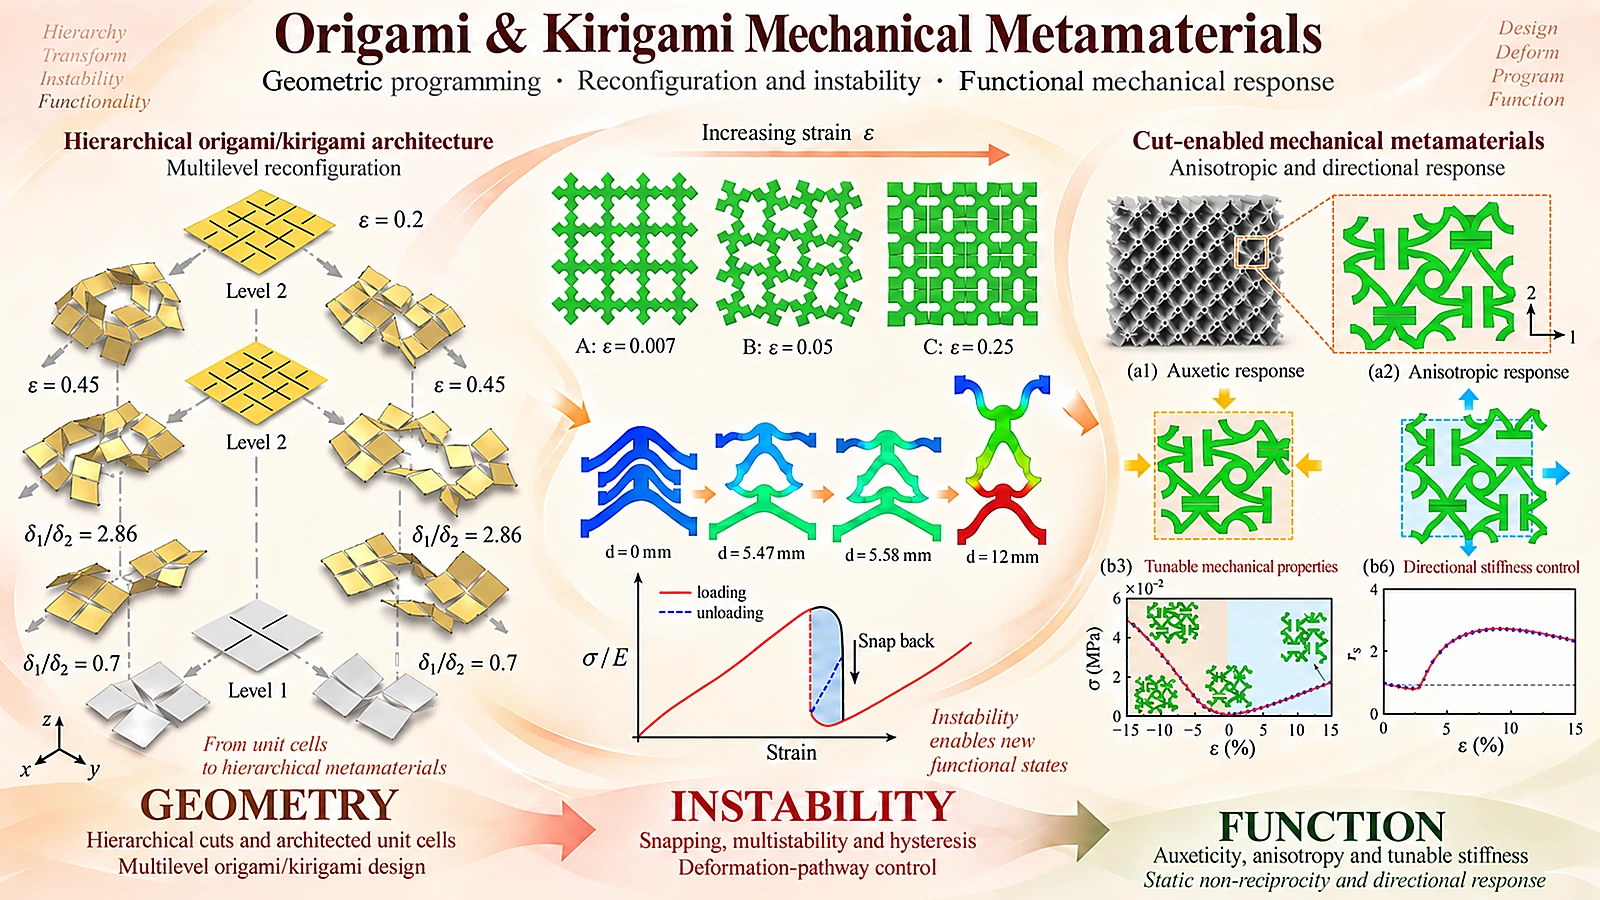
Origami & Kirigami Mechanical Metamaterials
We program reconfiguration and mechanical responses through folds, cuts, multistability, instability and architected geometries.
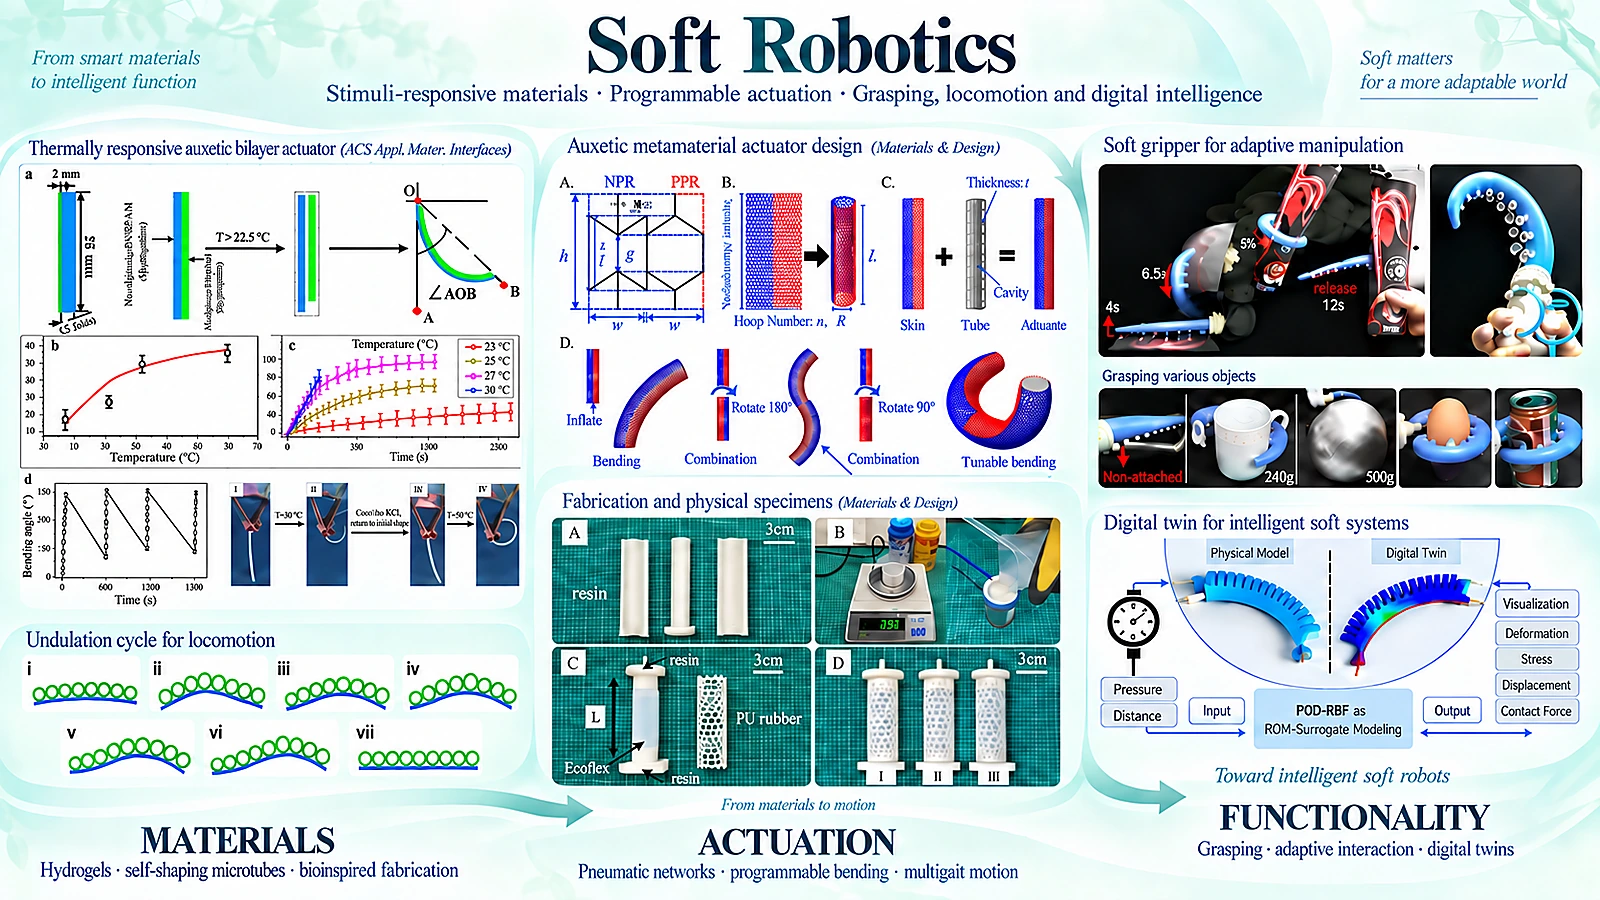
Soft Robotics
We combine smart materials, mechanical architectures and computational mechanics for programmable actuation, locomotion, grasping and intelligent interaction.